载物机器人在路口突然暂停A carrying robot pauses at a crossing
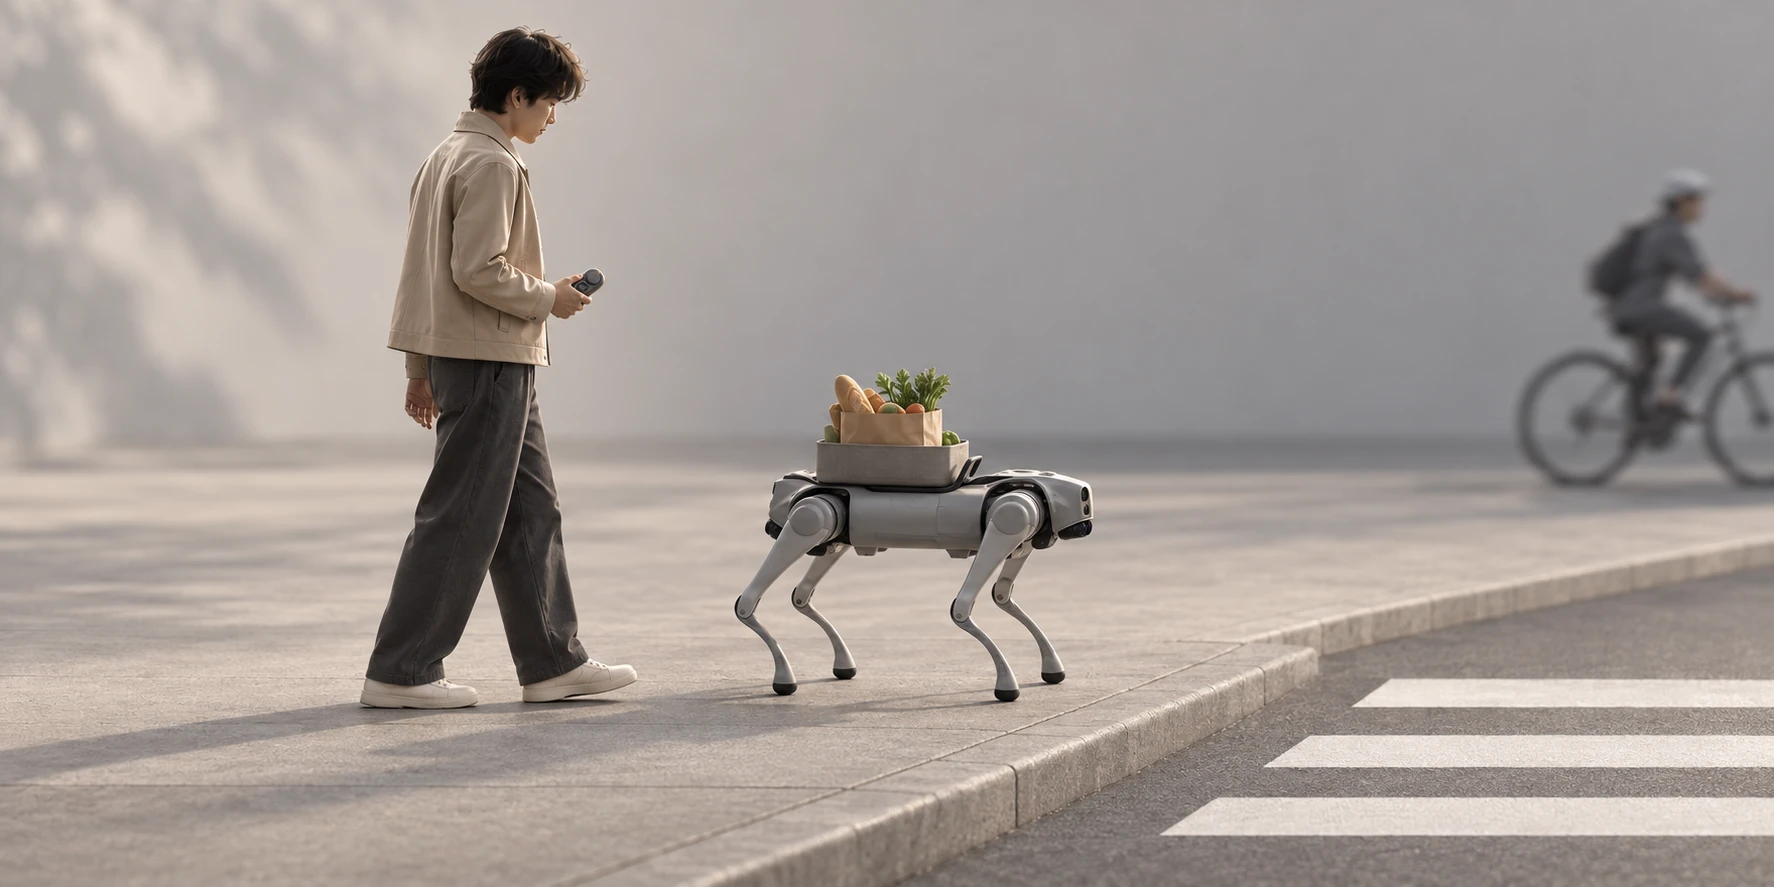
机器人暂停时,人需要知道原因,也需要能够回应When the robot pauses, people need its reason and a way to respond
目标用户与五项研究发现The target user and five research findings
看得见路、步行出行、让机器人帮忙载物的人People who can see the road, walk, and let a robot carry their things
- 典型一程A typical trip
- 从超市走回家,东西交给机器人,途中要过马路Walking home from the shops, the bags on the robot, crossing streets on the way
- 人负责The person
- 定方向和节奏,看路Sets the direction and pace, and watches the road
- 机器人负责The robot
- 载物、跟随,判断能不能过Carries, follows, and judges whether a crossing is clear
- 不在范围Out of scope
- 为视障者导盲 · 无人陪同的配送Guiding blind people · unaccompanied delivery
- 01
跟随载物的机器人已经在卖Following cargo robots are already on sale
gita plus 用摄像头认出主人并跟随,最多载 40 磅(约 18 公斤);它和轮椅、婴儿车一样走坡道,路缘和台阶要人帮忙。gita plus recognises its owner by camera and follows them, carrying up to 40 lb (about 18 kg). Like a wheelchair or a stroller it takes ramps; kerbs and stairs need a hand.
设计回应Design response为同行的人设计Design for the person walking alongside
- 02
路口的坡道,人和机器人都要用People and robots need the same kerb ramp
2019 年匹兹堡:一台配送机器人停在路缘坡道上,坐轮椅过街的人被困在车道里,来车正在靠近;大学随后暂停了这项服务。Pittsburgh, 2019: a delivery robot sat on a kerb ramp, leaving a wheelchair user stuck in the road as traffic approached. The university paused the service.
WESA · 2019-10-22E. Ackerman · Bloomberg CityLab · 2019-11-19
设计回应Design response等待时让开坡道Wait beside the ramp, never on it
- 03
过街时,眼睛离不开路At a crossing, eyes stay on the road
138 名大学生在虚拟街道上过马路:发短信或听音乐的人更容易被车撞,三组分心的人都更少看路。138 students crossed a virtual street. Those texting or listening to music were hit more often, and all three distracted groups looked at the road less.
设计回应Design response不用看的控制器A controller that works without looking
- 04
人会过度相信机器人People overtrust robots
模拟火警中,26 名参与者全部跟着机器人走,其中一半人几分钟前刚见过它带路表现很差。In a simulated fire, all 26 participants followed the robot, though half had watched it guide poorly minutes before.
设计回应Design response机器人提出方案,人来确认The robot proposes; the person confirms
- 05
说明原因,信任和表现都会提高Explanations raise trust and performance
在模拟的人机协作任务中,机器人自动说明自己的判断后,透明度、信任和团队表现都提高了。In a simulated human–robot team task, robots that explained their own decisions improved transparency, trust and team performance.
设计回应Design response每次停下都说明原因Every stop comes with a reason
一次出行的完整旅程One trip, from setting off to arrival
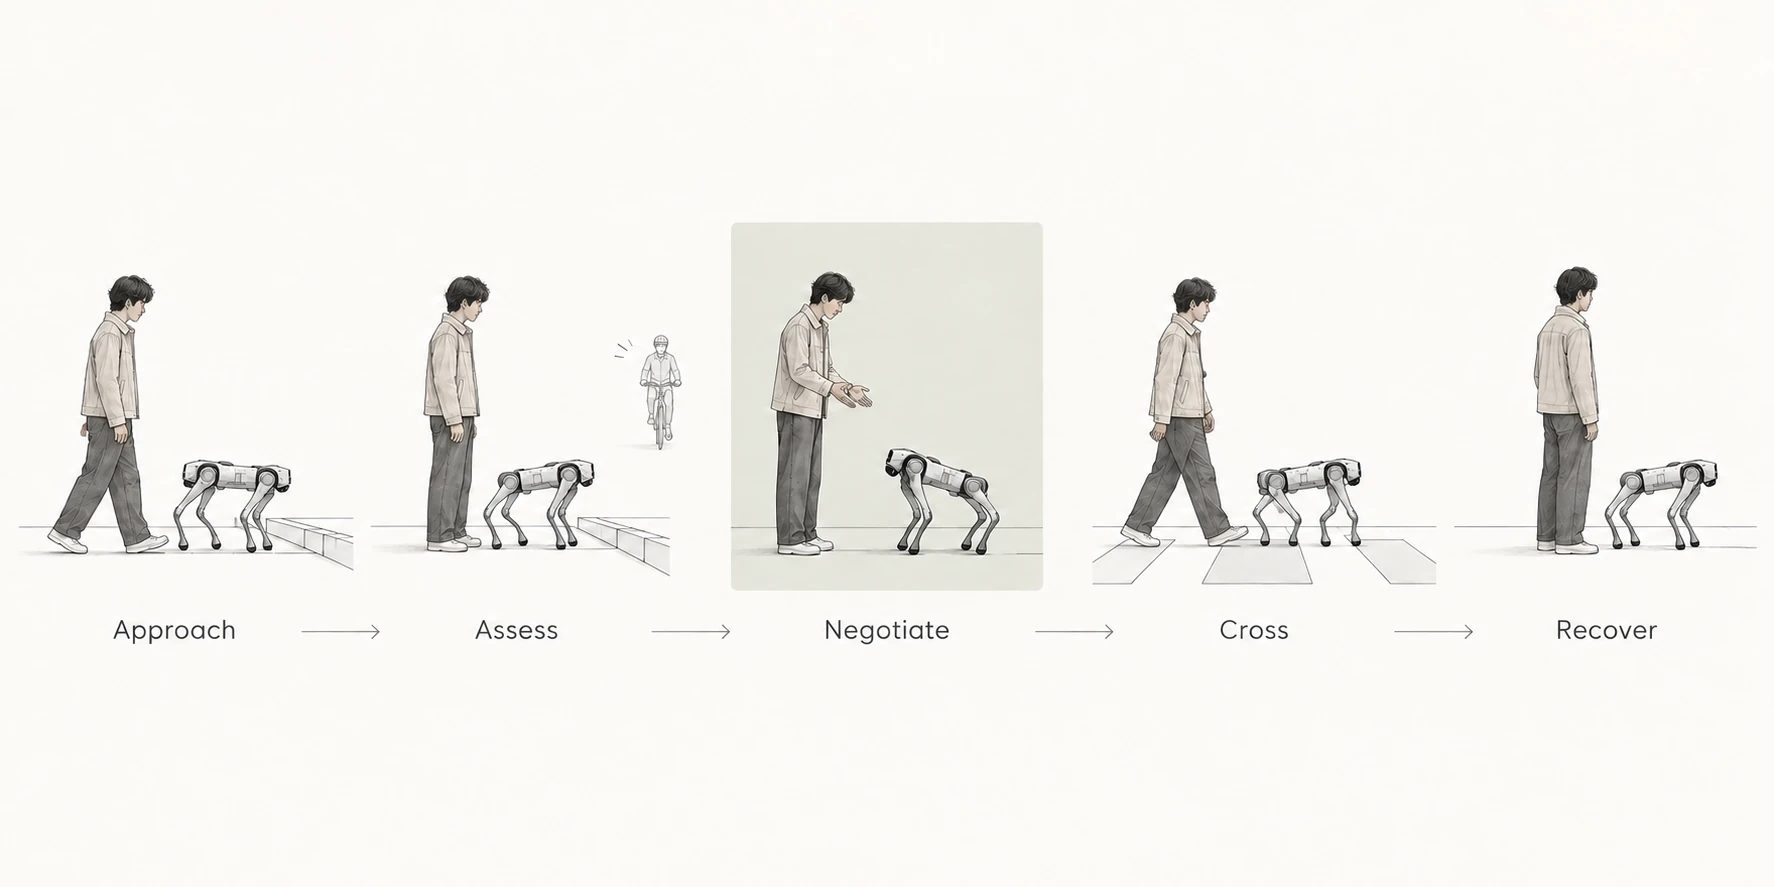
01出发Set off
决定Decision人主导Person leads
人Person放好东西,握住控制器Loads the robot and picks up the controller机器人Robot认出主人,开始跟随Recognises its owner and starts following控制器Controller长振Long语音Voice「我跟着你。」“I’m with you.”
02同行Walk together
决定Decision人主导Person leads
人Person按自己的节奏走,不用回头看Walks at their own pace, without looking back机器人Robot跟在身侧,配合步速Keeps to one side, matching the pace控制器Controller安静Silent语音Voice—03接近路口Approach
决定Decision机器人主导Robot leads
人Person看信号灯和来车Watches the lights and the traffic机器人Robot减速,评估路口Slows down and assesses the crossing控制器Controller轻振Tick语音Voice「前面是路口。」“Crossing ahead.”
04协商Negotiate
决定Decision共同决定Shared
人Person觉得可以走了,按「重判」Thinks it is clear and presses RECHECK机器人Robot在坡道一侧等待,说明原因,重判后提出方案Waits beside the ramp, gives its reason, checks again and proposes控制器Controller两次短振Double渐强Rising语音Voice「右边有骑车的人,先等一下。」→「骑车的人过去了,确认后出发。」“Cyclist on the right. Let’s wait.” → “They’ve passed. Confirm and we’ll go.”
05过街Cross
决定Decision共同决定Shared
人Person滑动确认,一起过街Slides CONFIRM and crosses with the robot机器人Robot按人的步速过街,到对面让开坡道Crosses at the person’s pace and clears the far ramp控制器Controller长振Long语音Voice「走吧。」“Let’s go.”
06到达Arrive
决定Decision人主导Person leads
人Person到家,取下东西Gets home and unloads机器人Robot停稳,等下一次出发Parks and waits for the next trip控制器Controller两次短振Double语音Voice「到了。」“We’re here.”
不低头看屏也能回应Responding without looking at a screen
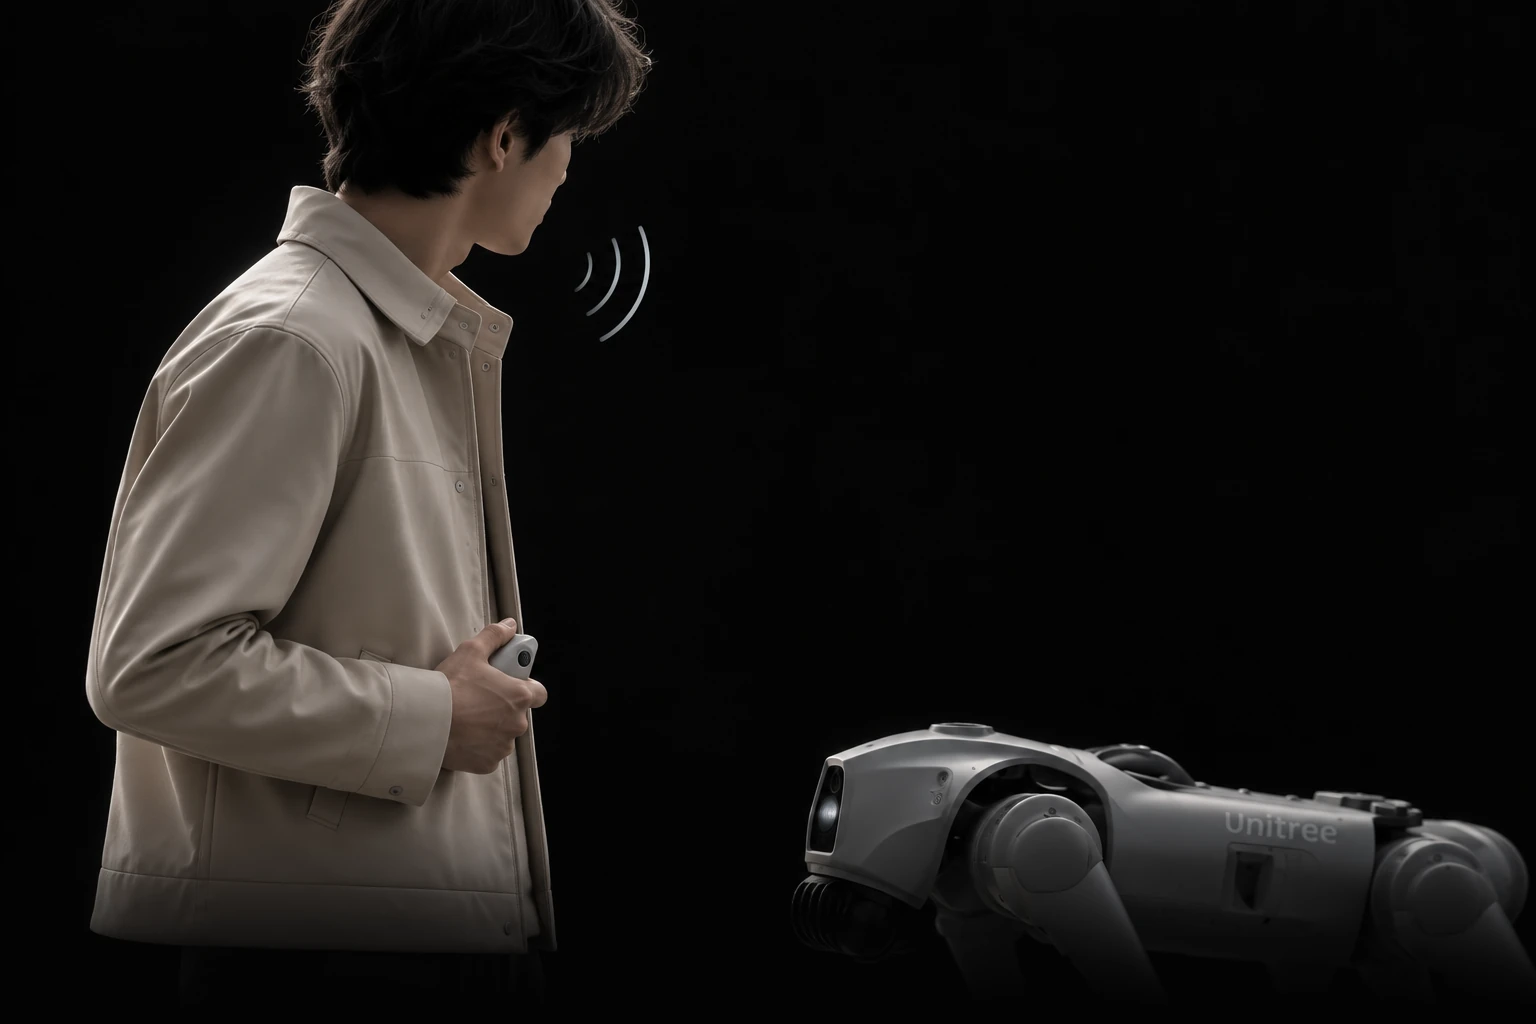
「我觉得他们停下了,
再判断一次。」“I think they’ve stopped.
Check again.”
「我重新评估,
我们先在这里等。」“I’ll reassess.
We’ll wait here.”
- 01 / 机器人01 / Robot说明暂停原因Explains the pause
- 02 / 人02 / Person请求重新判断Requests a recheck
- 03 / 机器人03 / Robot提出下一步方案Proposes the next move
- 04 / 人04 / Person确认方案Confirms the proposal
两种布局与三种可区分的手势Two layouts and three distinct gestures
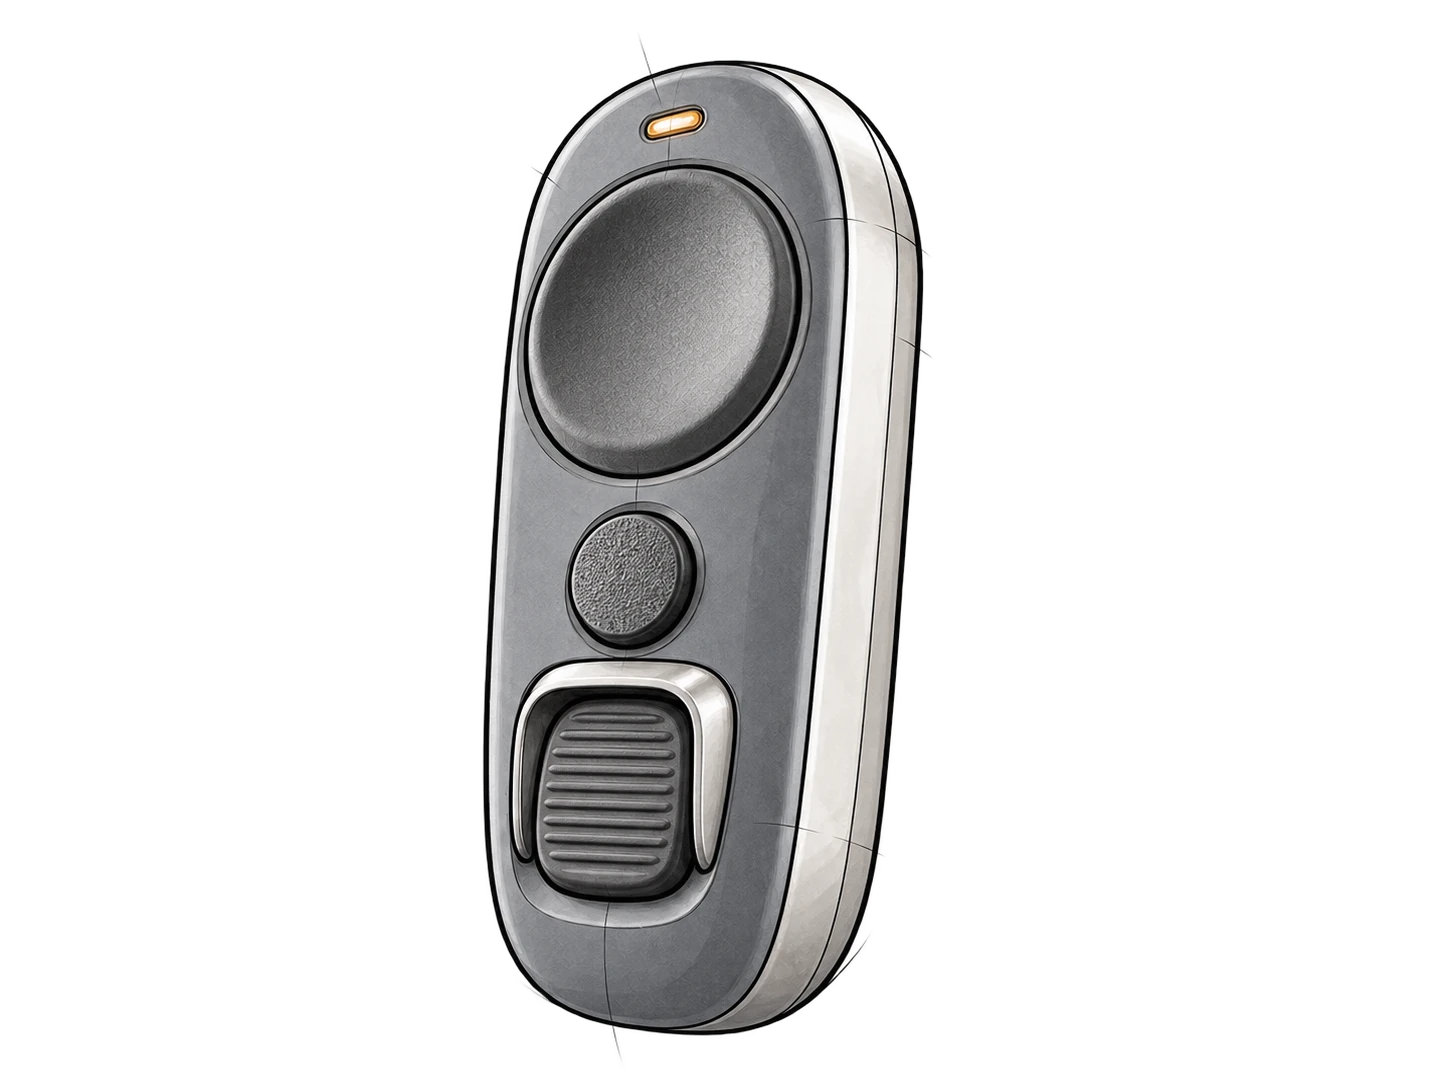
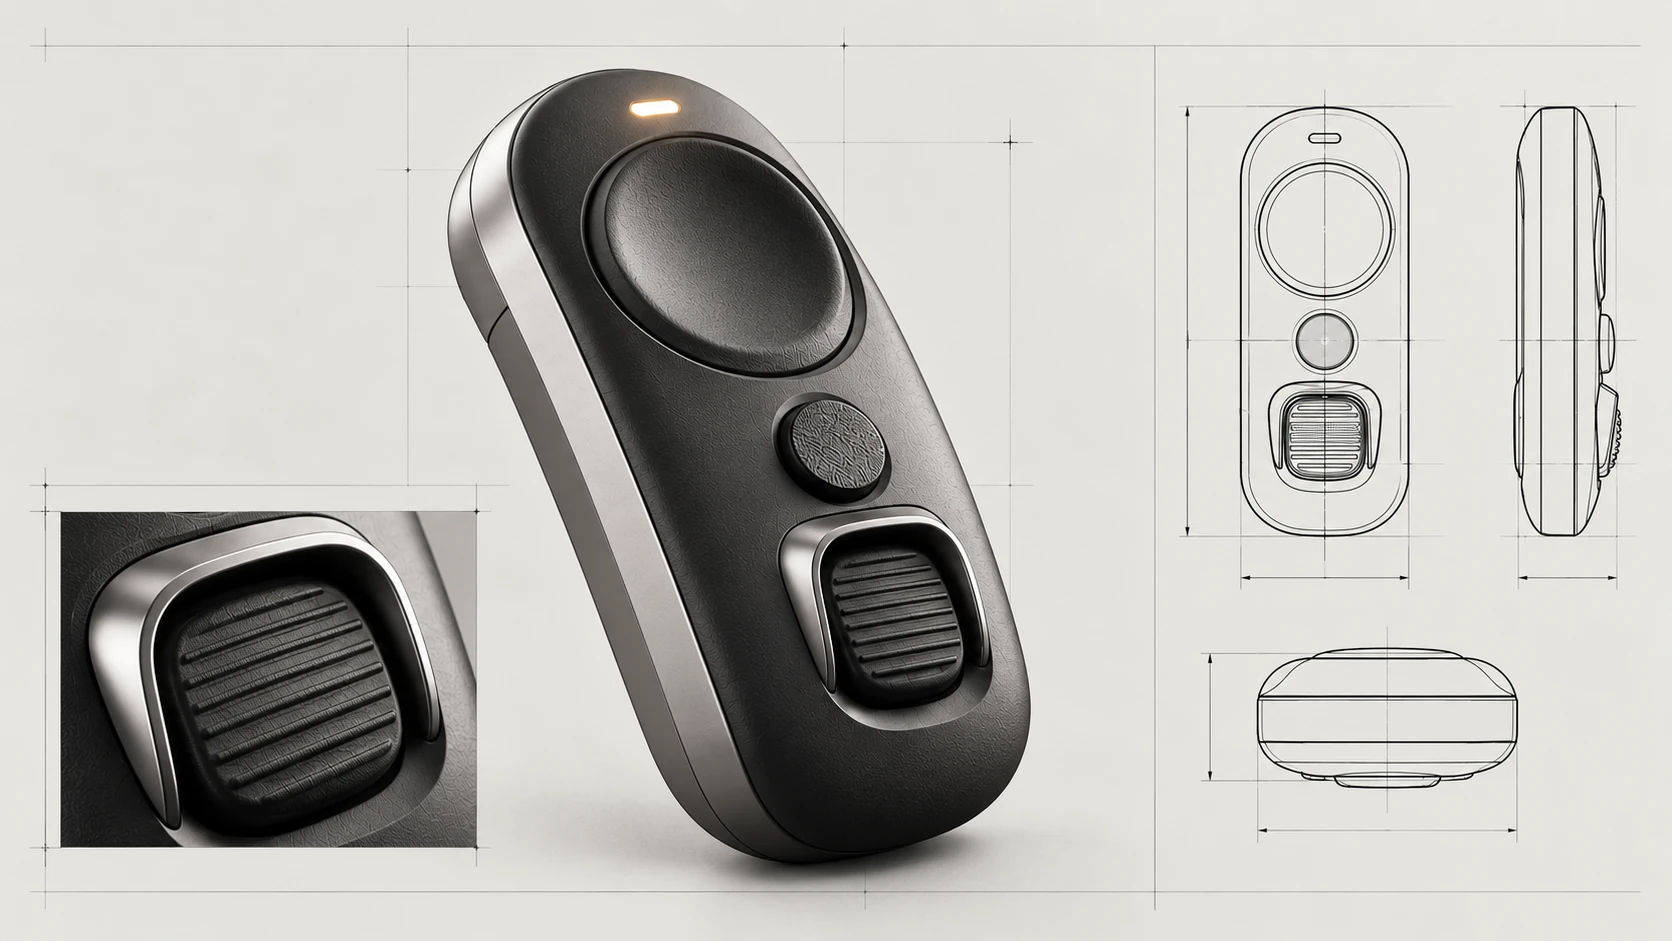
选定Selected正面集中布局Front-face controls
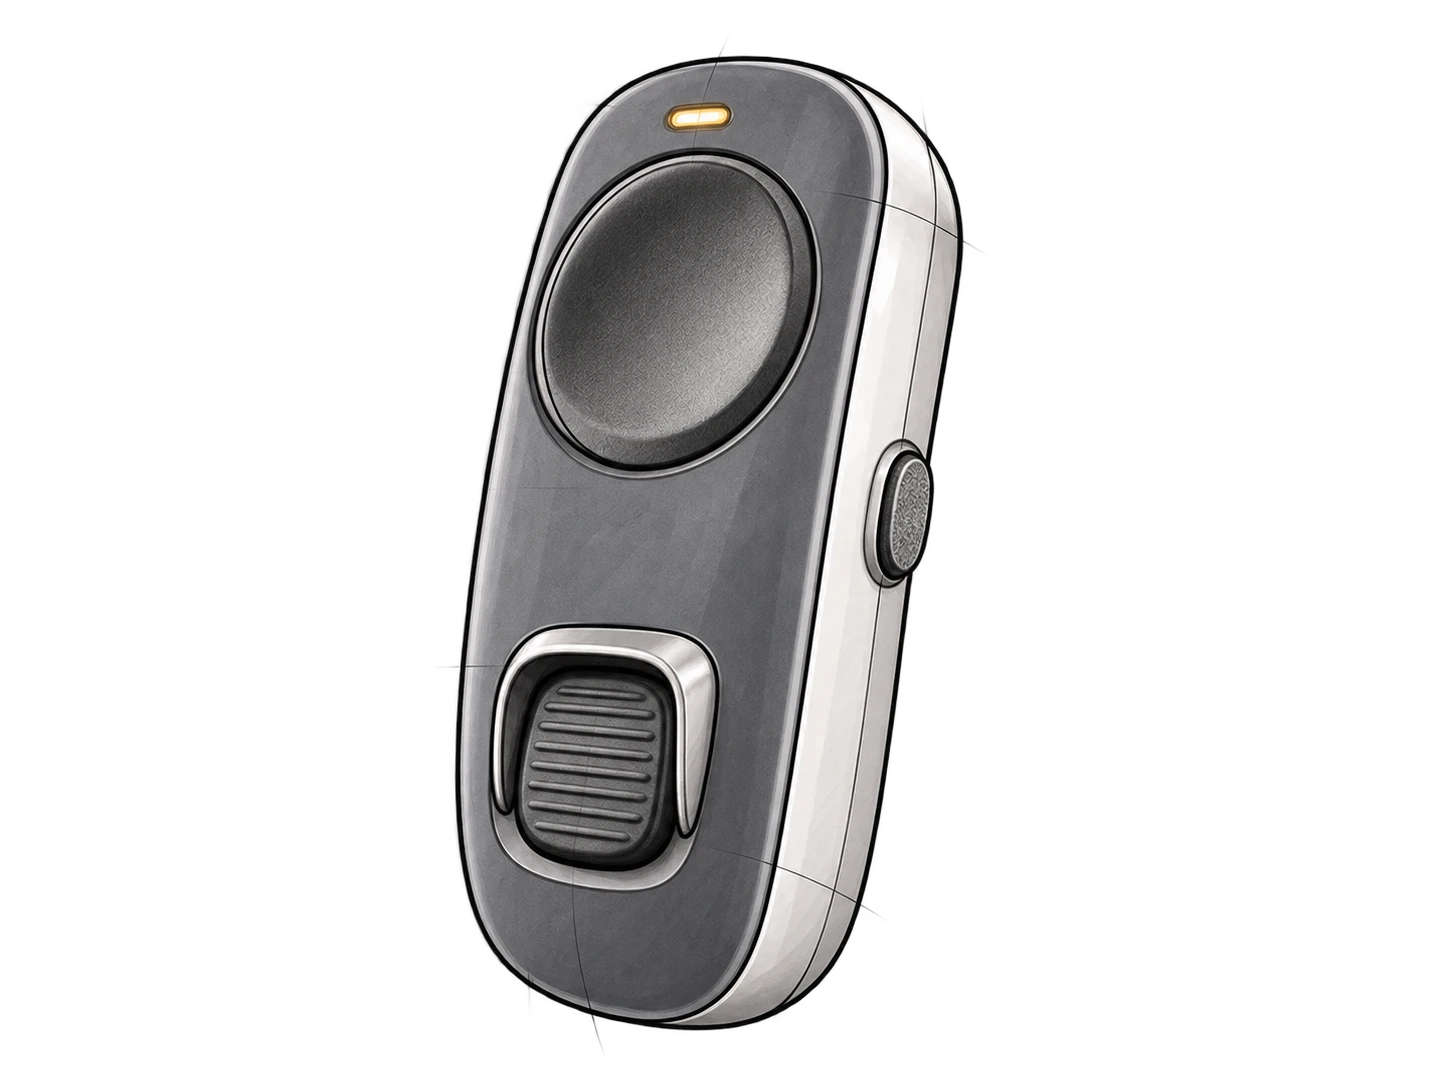
备选Alternative重判键在侧面RECHECK on the side
暂停、重判与确认Hold, recheck and confirm

HOLD
请求暂停。Request a pause.

RECHECK
请求重新评估。Request reassessment.

CONFIRM
接受当前方案。Accept the current proposal.
TACTILE CONTROL / CONCEPT

HOLD
凹面暂停键Concave pause pad
宽大的触摸面;「收到请求」与「已经停稳」需要分别反馈。A broad touch target; acknowledging the request and confirming the robot has stopped need separate feedback.
TACTILE CONTROL / CONCEPT


RECHECK
纹理重判键Textured recheck button
较小、有纹理的按键,在机器人等待时请求重新评估。A smaller, distinct surface requests a new assessment while the robot waits.
TACTILE CONTROL / CONCEPT
CONFIRM
受保护的确认滑块Guarded confirmation
需要有意滑动才能确认方案;出现新风险时,确认失效。A deliberate slide accepts the proposal. New risk cancels it.
七种状态的反馈与五种异常的处理Seven states with their feedback, and five exceptions
一次过街 · 七种状态One crossing · seven states
- 灯光Light
- 绿Green
- 振动Vibration
- 长振Long
机器人Robot「走吧。」“Let’s go.”
- 轻振Tick收到或提醒Received, or a heads-up
- 两次短振Double已停稳Stopped
- 渐强Rising有方案,可以确认A proposal to confirm
- 长振Long开始移动Moving off
- 两次低振Low double不行或已取消Not now, or cancelled
- 三次长振Three long连接中断Connection lost
01跟随Following
机器人Robot跟在人身侧,配合步速Walks beside the person at their pace
灯光Light白White
振动Vibration—
语音Voice—
可用控件Controls暂停HOLD
02前方路口Crossing ahead
机器人Robot减速,评估路口Slows down and assesses
灯光Light白 · 闪White, pulsing
振动Vibration轻振Tick
语音Voice
「前面是路口。」“Crossing ahead.”
可用控件Controls暂停HOLD
03等待Waiting
机器人Robot停在坡道一侧Stops beside the kerb ramp
灯光Light琥珀Amber
振动Vibration两次短振Double
语音Voice
「右边有骑车的人,先等一下。」“Cyclist on the right. Let’s wait.”
可用控件Controls暂停、重判HOLD, RECHECK
04重新判断Rechecking
机器人Robot原地不动,重新扫描Stays put and scans again
灯光Light琥珀 · 闪Amber, pulsing
振动Vibration轻振Tick
语音Voice
「好,我再看一次。」“OK, checking again.”
可用控件Controls暂停HOLD
05提出方案Proposal
机器人Robot停稳,准备过街Holds still, ready to cross
灯光Light绿 · 闪Green, pulsing
振动Vibration渐强Rising
语音Voice
「骑车的人过去了,确认后出发。」“The cyclist has passed. Confirm and we’ll go.”
可用控件Controls暂停、重判、确认HOLD, RECHECK, CONFIRM
06过街Crossing
机器人Robot按人的步速过街Crosses at the person’s pace
灯光Light绿Green
振动Vibration长振Long
语音Voice
「走吧。」“Let’s go.”
可用控件Controls暂停HOLD
07已暂停Paused
机器人Robot停稳,等人决定Holds still until the person decides
灯光Light琥珀Amber
振动Vibration轻振Tick两次短振Double
语音Voice
「好,停下了。」“OK, stopped.”
可用控件Controls暂停、重判、确认HOLD, RECHECK, CONFIRM
- 01随时可以按暂停HOLD works in every state
- 02先反馈「收到」,再反馈「停稳」“Received” comes before “stopped”
- 03每次等待都说明原因Every wait comes with a reason
- 04确认只对当前方案有效CONFIRM only accepts the current proposal
五种异常情况,以及各自回到的状态Five exceptions and where each one returns
- 01
误按暂停HOLD pressed by accident
机器人Robot照样停下,再等人决定Stops anyway, then waits for the person
控制器Controller轻振Tick两次短振Double
语音Voice
「好,停下了。滑动确认就继续。」“OK, stopped. Slide to carry on.”
回到Then07已暂停Paused
- 02
确认后出现新风险New risk after CONFIRM
机器人Robot不出发,方案作废Does not set off; the proposal is void
控制器Controller两次低振Low double滑块复位The slider resets
语音Voice
「左边来车了,先等。」“Car from the left. Wait.”
回到Then03等待Waiting
- 03
过街途中按暂停HOLD in the middle of the road
机器人Robot不停在车道上,到对面再停;人停下时,守在人身边Stops on the far side, never in the road; stays beside the person if they stop
控制器Controller轻振Tick
语音Voice
「在路中间,到对面再停。」“We’re mid-road. I’ll stop on the other side.”
回到Then07已暂停Paused
- 04
人坚持要走The person insists on going
机器人Robot留在路边,确认安全后再跟上Stays at the kerb and follows once it is clear
控制器Controller两次低振Low double
语音Voice
「收到。右边还有车。」“I hear you. There’s still a car on the right.”
回到Then03等待Waiting
- 05
连接中断Connection lost
机器人Robot过街途中先到对面,再停到安全处等待Finishes any crossing, then waits somewhere safe
控制器Controller三次长振Three long
语音Voice
「和控制器断开了,我在这里等你。」“I’ve lost the controller. I’ll wait here.”
回到Then07已暂停Paused
正面集中布局的手持控制器A handheld controller with front-face controls
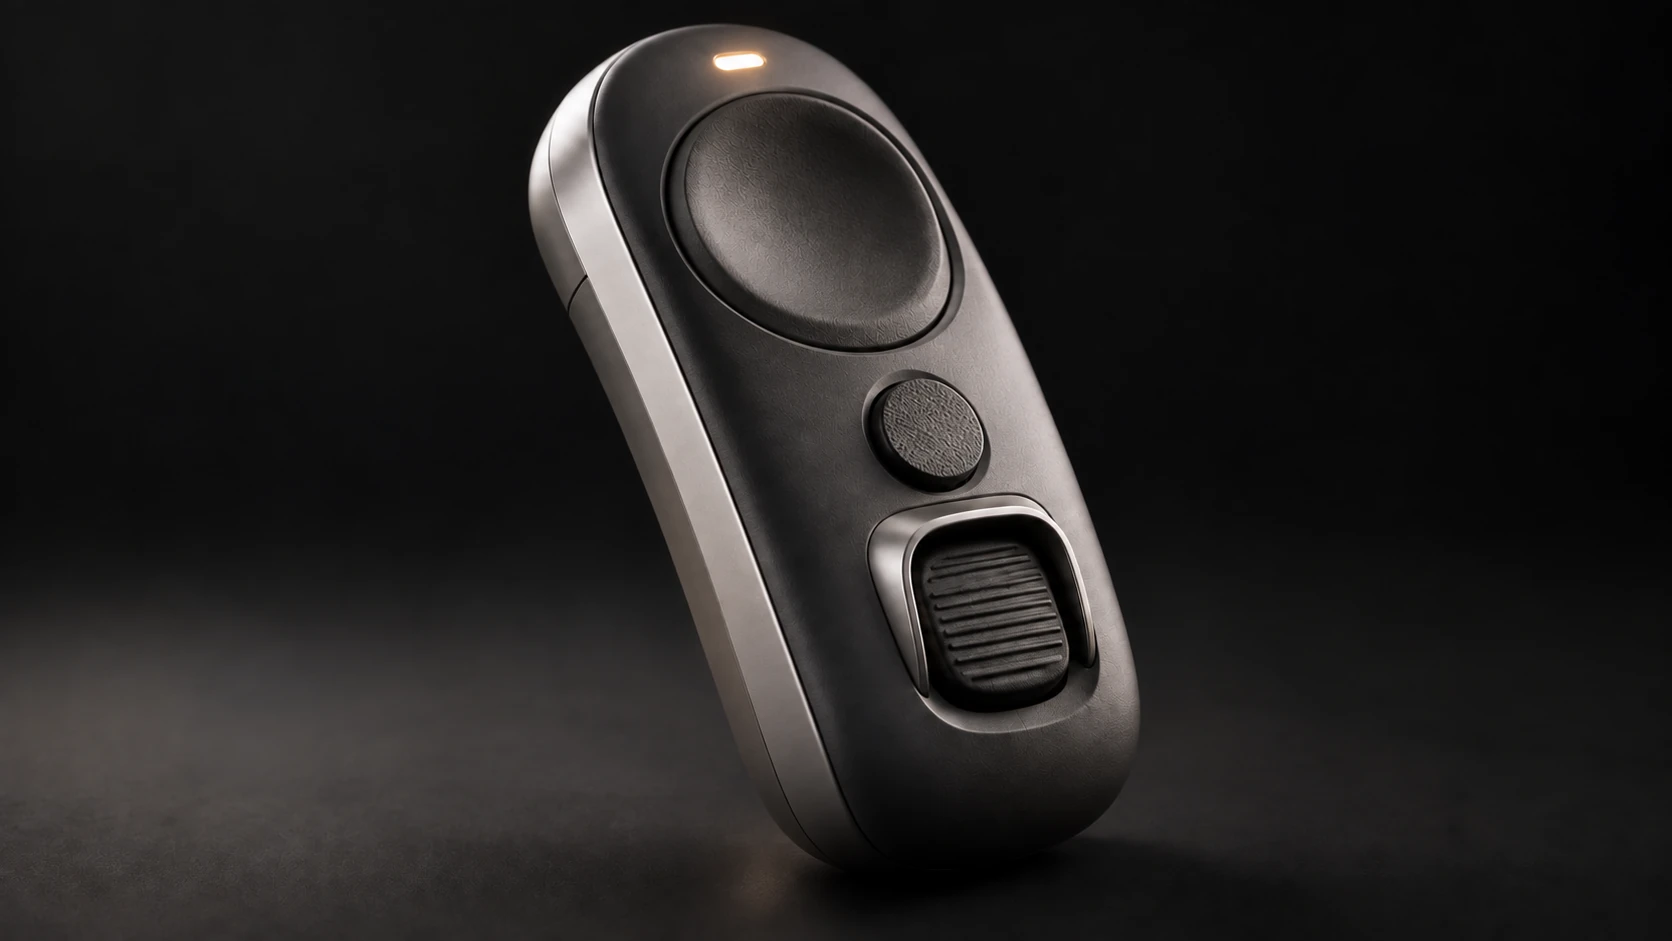
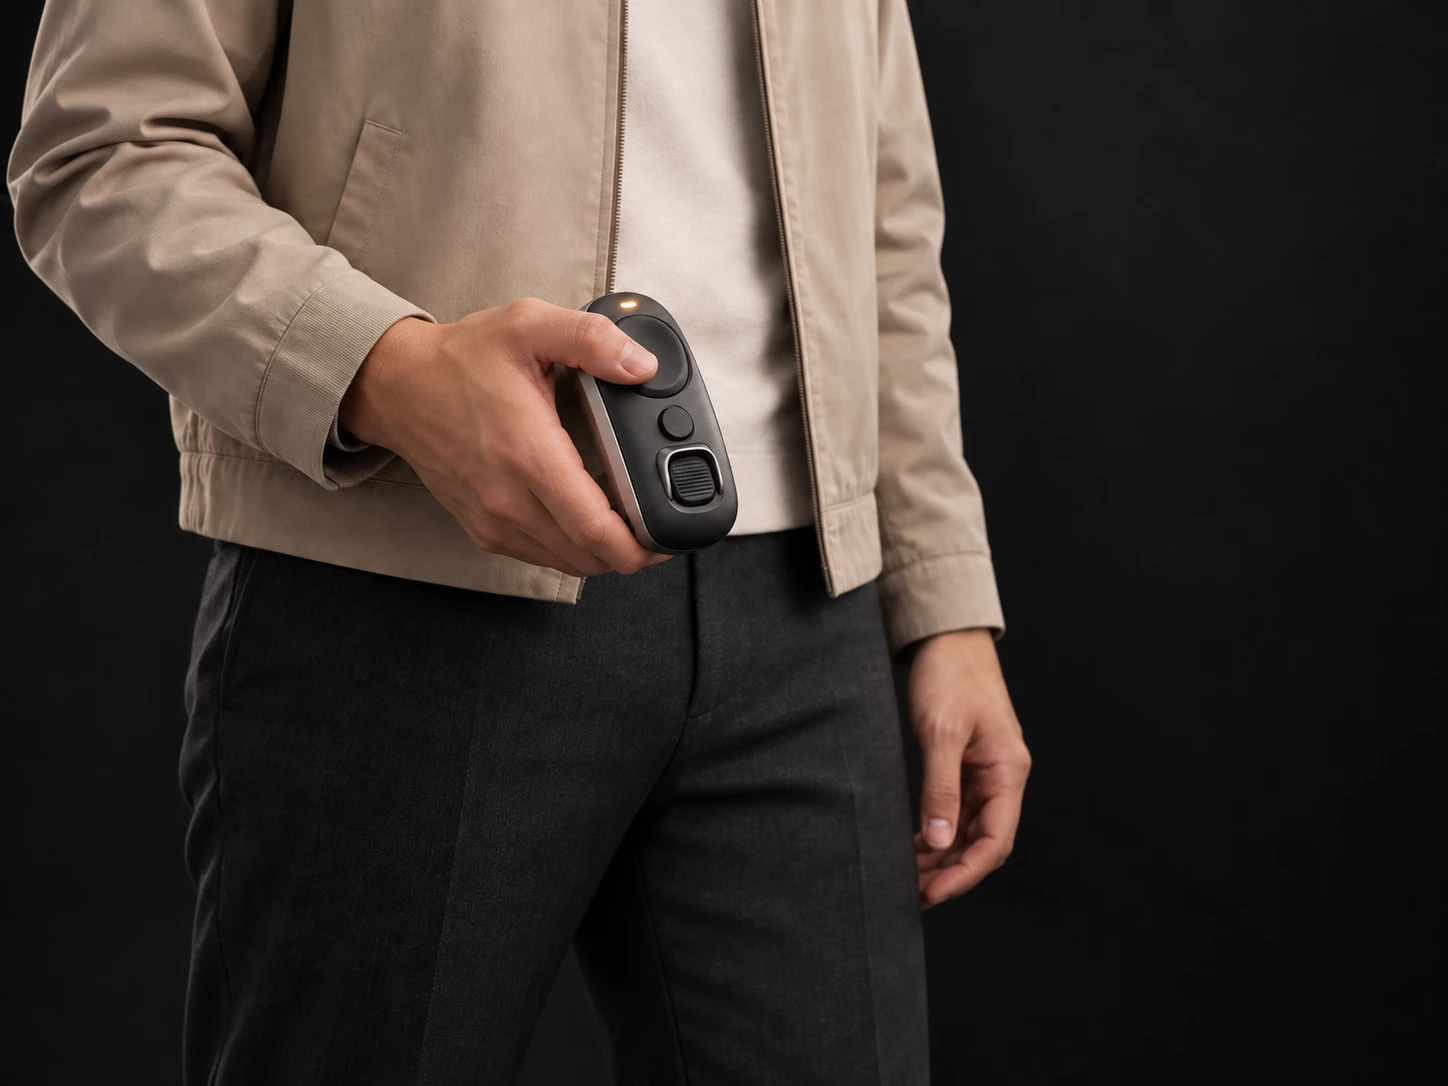
CONTROL ACTIONS
HOLD
request pause · await acknowledgement
RECHECK
request a new risk assessment
CONFIRM
confirm a current proposal to move
逐层拆解:从触觉表面到后壳Layer by layer: from tactile surface to back shell
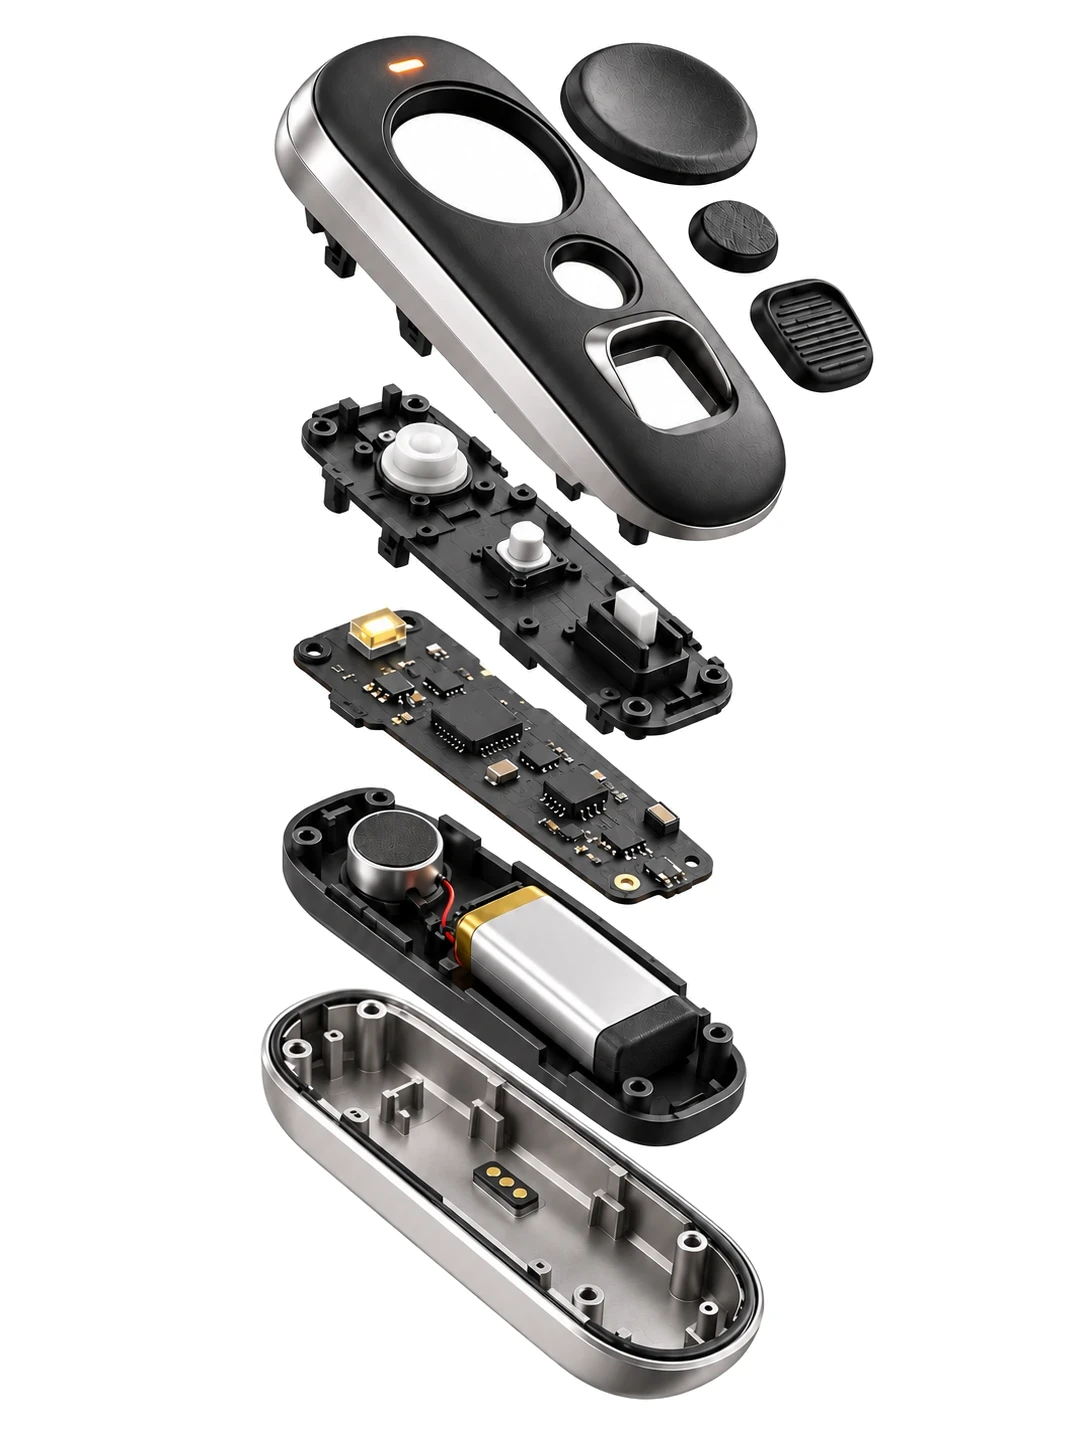
- 触觉表面Tactile surface
- 凹面键、纹理键与受保护的滑块。Concave pad, textured button and guarded slider.
- 输入支架Input carrier
- 分隔并支撑三个控件。Separates and supports the three controls.
- 控制板Control board
- 输入与确认反馈层。Input and acknowledgement layer.
- 反馈与电源Feedback + power
- 反馈执行器与可充电电池。Feedback actuator and rechargeable cell.
- 后壳Rear housing
- 连续贴合手掌的接触面。Continuous palm contact surface.
可交互的脚本原型An interactive scripted prototype
路口 · 脚本模拟Crossing · scripted simulation
等待你的确认Ready for confirmation
载物机器人在路口暂停。请选择你的回应。A carrying robot pauses at a crossing. Choose your response.
移动状态:已停止Movement: stopped
概念模拟 · 不是导航指令Concept simulation · not a navigation instruction
机器人Robot
已收到你的请求。我在保持暂停的同时重新做了评估。Your request was received. I reassessed while we stayed paused.
在这个场景中,骑车的人已经通过了我们要穿过的路线。我建议继续前进。你准备好了吗?The cyclist has now passed our crossing path in this scenario. I suggest continuing. Are you ready?
机器人Robot
已暂停。Paused.
机器人Robot
侧面有骑车的人靠近,我不确定对方会不会停下。我建议先等待。A cyclist is approaching from the side. I’m not sure they will stop. I suggest waiting.
体验方案、手持控制器、三个控件与脚本原型Experience model, handheld controller, three controls and scripted prototype
体验方案Experience model
- 六段出行旅程:从出发到到达A six-stage trip, from setting off to arrival
- 七种状态,各有对应的灯光、振动与语音Seven states, each with its light, vibration and voice
- 五种异常处理,各自回到明确的状态Five exceptions, each returning to a known state
手持控制器Handheld controller
正面集中布局:凹面、纹理与受保护的滑块Front-face layout; concave, textured and guarded-slide controls
三个控件Three controls
- 暂停 · 请求暂停HOLD · request a pause
- 重判 · 请求重新评估RECHECK · ask for a new assessment
- 确认 · 同意当前方案CONFIRM · accept the current proposal
脚本原型Scripted prototype
可点击演示:暂停、说明原因、重判与确认A clickable walkthrough: pause, reason, recheck and confirm